> For the complete documentation index, see [llms.txt](https://docs.gremsy.com/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://docs.gremsy.com/payloads/general/troubleshooting/gremsy-flight-controller-connection-verification-guide.md).
# Gremsy – Flight Controller Connection Verification Guide
### **1. Purpose**
This document describes how to verify whether the **Gimbal** is properly connected to the **Flight Controller (FC)** via UART (MAVLink protocol).
***
### **2. Method 1: LED Status Check**
#### **Procedure**
* Observe the **status LED** on the gimbal.
#### **Expected Result**
* **Pink / Purple LED** → Gimbal is successfully connected to the Flight Controller.
* Any other color → Connection may not be established.
***
### **3. Hardware Connection**
#### **UART Wiring**
* Connect the gimbal UART to **TELEM2** port on the Flight Controller.
#### Mavlink Autopilot Setup
#### **Notes**
* Ensure correct **TX/RX crossover**
* Verify stable **power supply**
* Confirm cable integrity
***
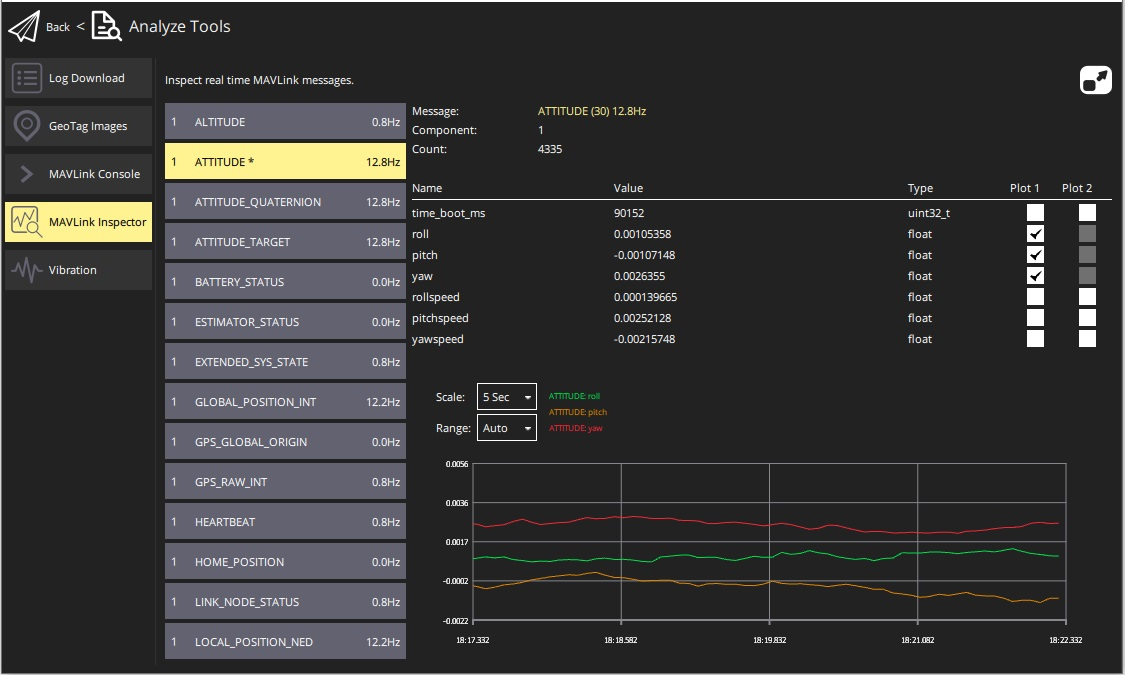
### **4. Method 2: MAVLink Inspector**
#### **Procedure**
1. Open **QGroundControl/Mission Planner**
2. Navigate to:\
**Analyze Tools → MAVLink Inspector**
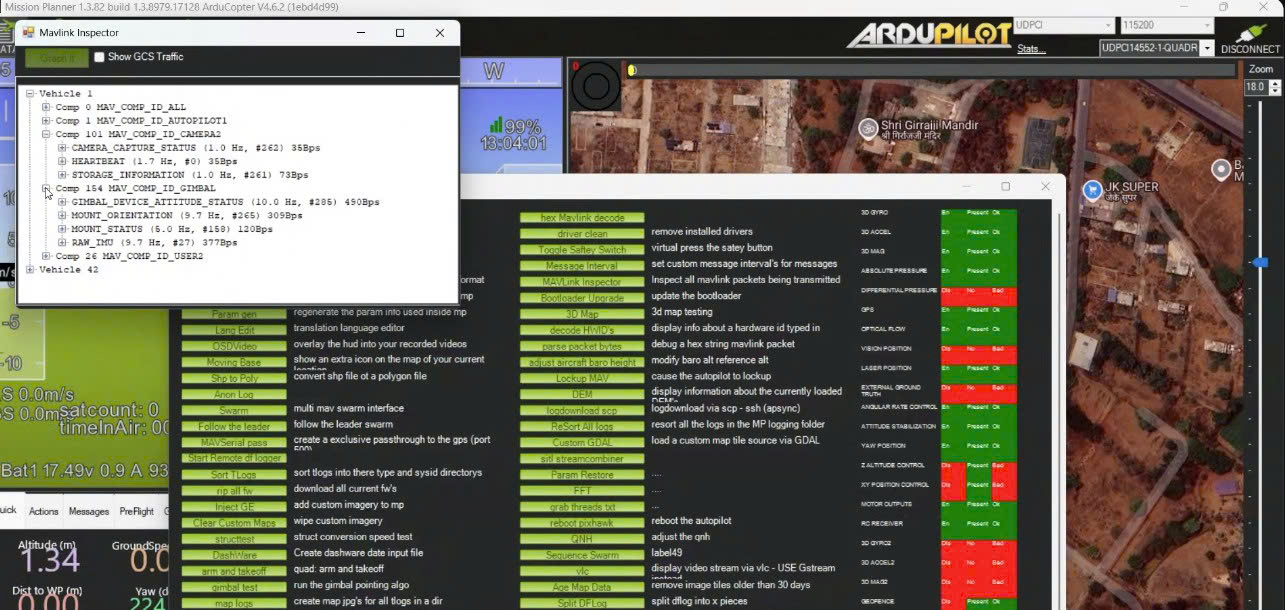
3. Monitor the incoming MAVLink components
#### **Expected Component IDs**
| Component | ID | Description |
| --------- | --- | --------------------------- |
| Payload | 101 | VIO / ZIO / Orus-L payloads |
| Gimbal | 154 | Gimbal system |
#### **Result Interpretation**
* Both **Component ID 101 and 154 detected** → Connection confirmed
* Missing one or both → Connection issue exists
***
### **5. Troubleshooting**
If no components are detected:
#### **5.1 UART Connection**
* Verify TX/RX wiring is correct
* Check for loose or damaged cables
#### **5.2 Flight Controller Parameters**
* Ensure MAVLink is enabled on **TELEM2**
* Verify correct **baud rate** (typically **115200** or configured value)
#### **5.3 Power Supply**
* Confirm the gimbal is powered properly
#### **5.4 Signal Measurement**
* Use a multimeter or oscilloscope:
* Check **TX signal activity**
* Verify voltage levels (\~3.3V or 5V depending on system)
***
### **6. Quick Verification Summary**
| Check Method | Expected Result |
| ----------------- | ------------------------------- |
| LED Status | Pink/Purple |
| MAVLink Inspector | Component ID 101 & 154 detected |
***
### **7. Conclusion**
A valid connection is confirmed when:
* The gimbal LED indicates **Pink/Purple**, and
* MAVLink Inspector shows both **Component ID 101 and 154**
---
# Agent Instructions
This documentation is published with GitBook. GitBook is the documentation platform designed so that both humans and AI agents can read, navigate, and reason over technical content effectively. Learn more at gitbook.com.
## Querying This Documentation
If you need additional information that is not directly available in this page, you can query the documentation by asking a question.
Perform an HTTP GET request on the following URL with the `ask` and `goal` query parameters:
```
GET https://docs.gremsy.com/payloads/general/troubleshooting/gremsy-flight-controller-connection-verification-guide.md?ask=&goal=
```
`ask` is the immediate question: it should be specific, self-contained, and written in natural language.
`goal` is what the user is ultimately trying to achieve, the reason they need the answer. Sharing it helps GitBook give you a better, more relevant answer. A goal is most helpful when it describes the outcome the user wants rather than restating the question. For example, with `ask=how do I create an API token`, a goal like `automate deployments from our CI pipeline` lets GitBook tailor the answer to that use case.
The response will contain a direct answer to the question and relevant excerpts and sources from the documentation.
Use this mechanism when the answer is not explicitly present in the current page, you need clarification or additional context, or you want to retrieve related documentation sections.