> For the complete documentation index, see [llms.txt](https://docs.gremsy.com/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://docs.gremsy.com/gimbals/mio/getting-started/introduction.md).
# Introduction
MIO
## OVERVIEW
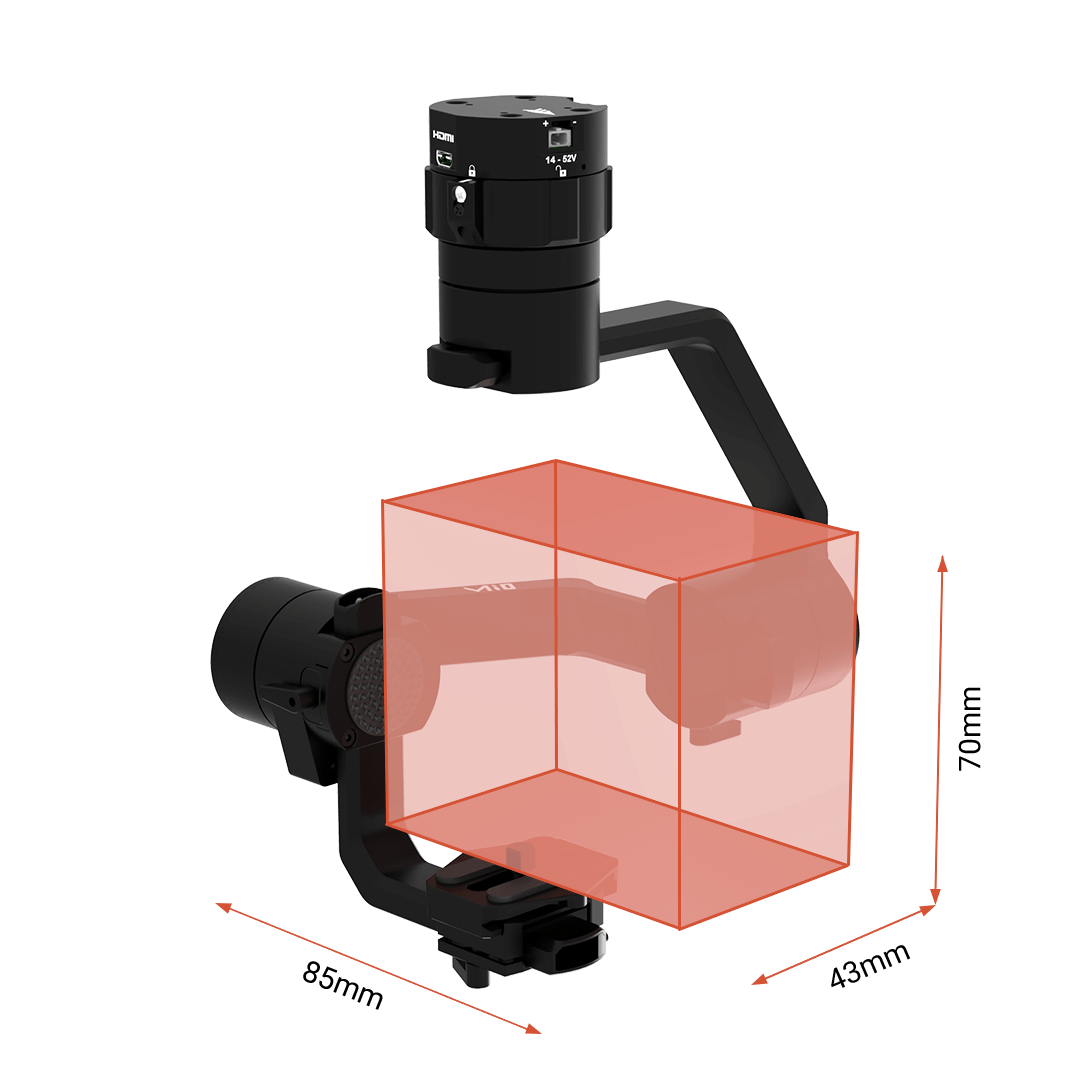
MIO is an ultra lightweight 3-axis gimbal that is specially designed for a wide variety of small cameras, features Hyper-quick release with integrated HDMI, a variety of I/O interfaces and ability to start up in 2 seconds.
Smaller and lighter than ever, Mio is the smartphone-sized gimbal tailored to meet the needs of industrial uses.
## FEATURES
### HDMI HYPER QUICK RELEASE
New mechanical and electrical integration quick release features high-speed connectors allow for HDMI transmission and other I/O interface. A variety of ports on QR allow quick interface with multiple devices such as third party flight controllers, remote control, and auxiliary I/O.
### UNIVERSAL
The ability to adjust balancing in 3 axis allows MIO to mount a wide range of cameras such as Flir DUO Pro R, Flir Vue Pro, Flir Vue, Sony R10C, Sony QX1, Rededge MX, Sony RX0 I, Sony RX0 II.
### HEATED & TEMPERATURE CONTROLLED IMU
Heated and temperature controlled IMU sensor allowing reliable performance even in extreme weather. Temperature is maintained within 0.2 degrees Celsius accuracy.
### HIGH PERFORMANCE GIMBAL CONTROLLER
Advanced gimbal controller designed and made by Gremsy based on a 32 bit high performance ARM microprocessor providing fast response and accurate calculation. Sensor data and motors correction are updated as fast as 2000 times per second to enable incredibly smooth footage.
### CLEAN DESIGN - INTERNAL WIRING
No exterior wires, more solid. This clean design helps the MIO overcome wind resistance with ease to bring out the best video quality while staying agile.
### BUILT FOR AERIAL WORK
Super light-weight and very small form factor, MIO could be mounted to various flying platforms and enable longer flight time.
---
# Agent Instructions
This documentation is published with GitBook. GitBook is the documentation platform designed so that both humans and AI agents can read, navigate, and reason over technical content effectively. Learn more at gitbook.com.
## Querying This Documentation
If you need additional information that is not directly available in this page, you can query the documentation by asking a question.
Perform an HTTP GET request on the following URL with the `ask` and `goal` query parameters:
```
GET https://docs.gremsy.com/gimbals/mio/getting-started/introduction.md?ask=&goal=
```
`ask` is the immediate question: it should be specific, self-contained, and written in natural language.
`goal` is what the user is ultimately trying to achieve, the reason they need the answer. Sharing it helps GitBook give you a better, more relevant answer. A goal is most helpful when it describes the outcome the user wants rather than restating the question. For example, with `ask=how do I create an API token`, a goal like `automate deployments from our CI pipeline` lets GitBook tailor the answer to that use case.
The response will contain a direct answer to the question and relevant excerpts and sources from the documentation.
Use this mechanism when the answer is not explicitly present in the current page, you need clarification or additional context, or you want to retrieve related documentation sections.